Thursday, August 1, 2024 | 12:00 – 1:00 PM (ET)
Vehicle scheduling in roadway conflict areas is a pervasive and complex challenge. The sheer volume of vehicles exacerbates the time-consuming nature of solving the scheduling problem, rendering it inadequate for real-time operational needs. To address this issue effectively, this study introduces a platooning strategy for connected automated vehicles when traversing through general conflict areas. The proposed strategy aggregates vehicles into platoons, treating each platoon as a scheduling unit, thereby reducing the problem’s complexity. The heterogeneity of the vehicle is simultaneously transformed into the characteristics of the platoon. Theoretical analyses demonstrate that the disparity in optimal solutions (in terms of vehicle delay) between the single-vehicle-based strategy and the proposed platoon-based strategy is bounded. Furthermore, numerical experiments further validate the effectiveness of the proposed strategy, showing its superiority in reducing the scheduling problem size without significant compromise to solution optimality. These findings contribute to the domain of network control in realistic settings with heterogeneous vehicles, addressing the challenges associated with coordinating diverse vehicle types efficiently. By leveraging platooning and treating platoons as scheduling units, the proposed strategy improves scalability and enhances the potential for real-time network control in heterogeneous vehicle environments.
About the Presenters:
Dr. Xiaopeng (Shaw) Li is currently a Professor in the Department of Civil and Environmental Engineering and an affiliate in the Department of Electrical and Computer Engineering at the University of Wisconsin-Madison (UW-Madison). He served as the director of National Institute for Congestion Reduction (NICR) before. He is a recipient of a National Science Foundation (NSF) CAREER award. He has published over 120 peer-reviewed journal papers. He has served as the PI or a co-PI for a number of federal, state, and industry grants, with a total budget of around $30 million. His major research interests include automation, connectivity, and sensing in transportation and related systems. He received a B.S. degree (2006) in civil engineering with a minor in computer engineering from Tsinghua University, China, an M.S. degree (2007), and a Ph.D. (2011) degree in civil engineering along with an M.S. degree (2010) in applied mathematics from the University of Illinois at Urban-Champaign, USA.
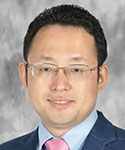
Keke Long is a Research Assistant in the Department of Civil and Environmental Engineering at University of Wisconsin, Madison, Madison, WI, USA. She obtained her Master’s degree in Traffic Engineering from Tongji University, Shanghai, China in 2021 and B.S. degree in Traffic Engineering from Changan University, Xi’an, China in 2018. Her main research interests are connected and autonomous vehicles and artificial intelligence application in transportation.